EPGL-200-1200 Heavy-Load Gripper
EPGL-200-1200 is listed in the EPGL series for long-stroke heavy-load handling. Compare the model data with your workpiece and installation requirements.
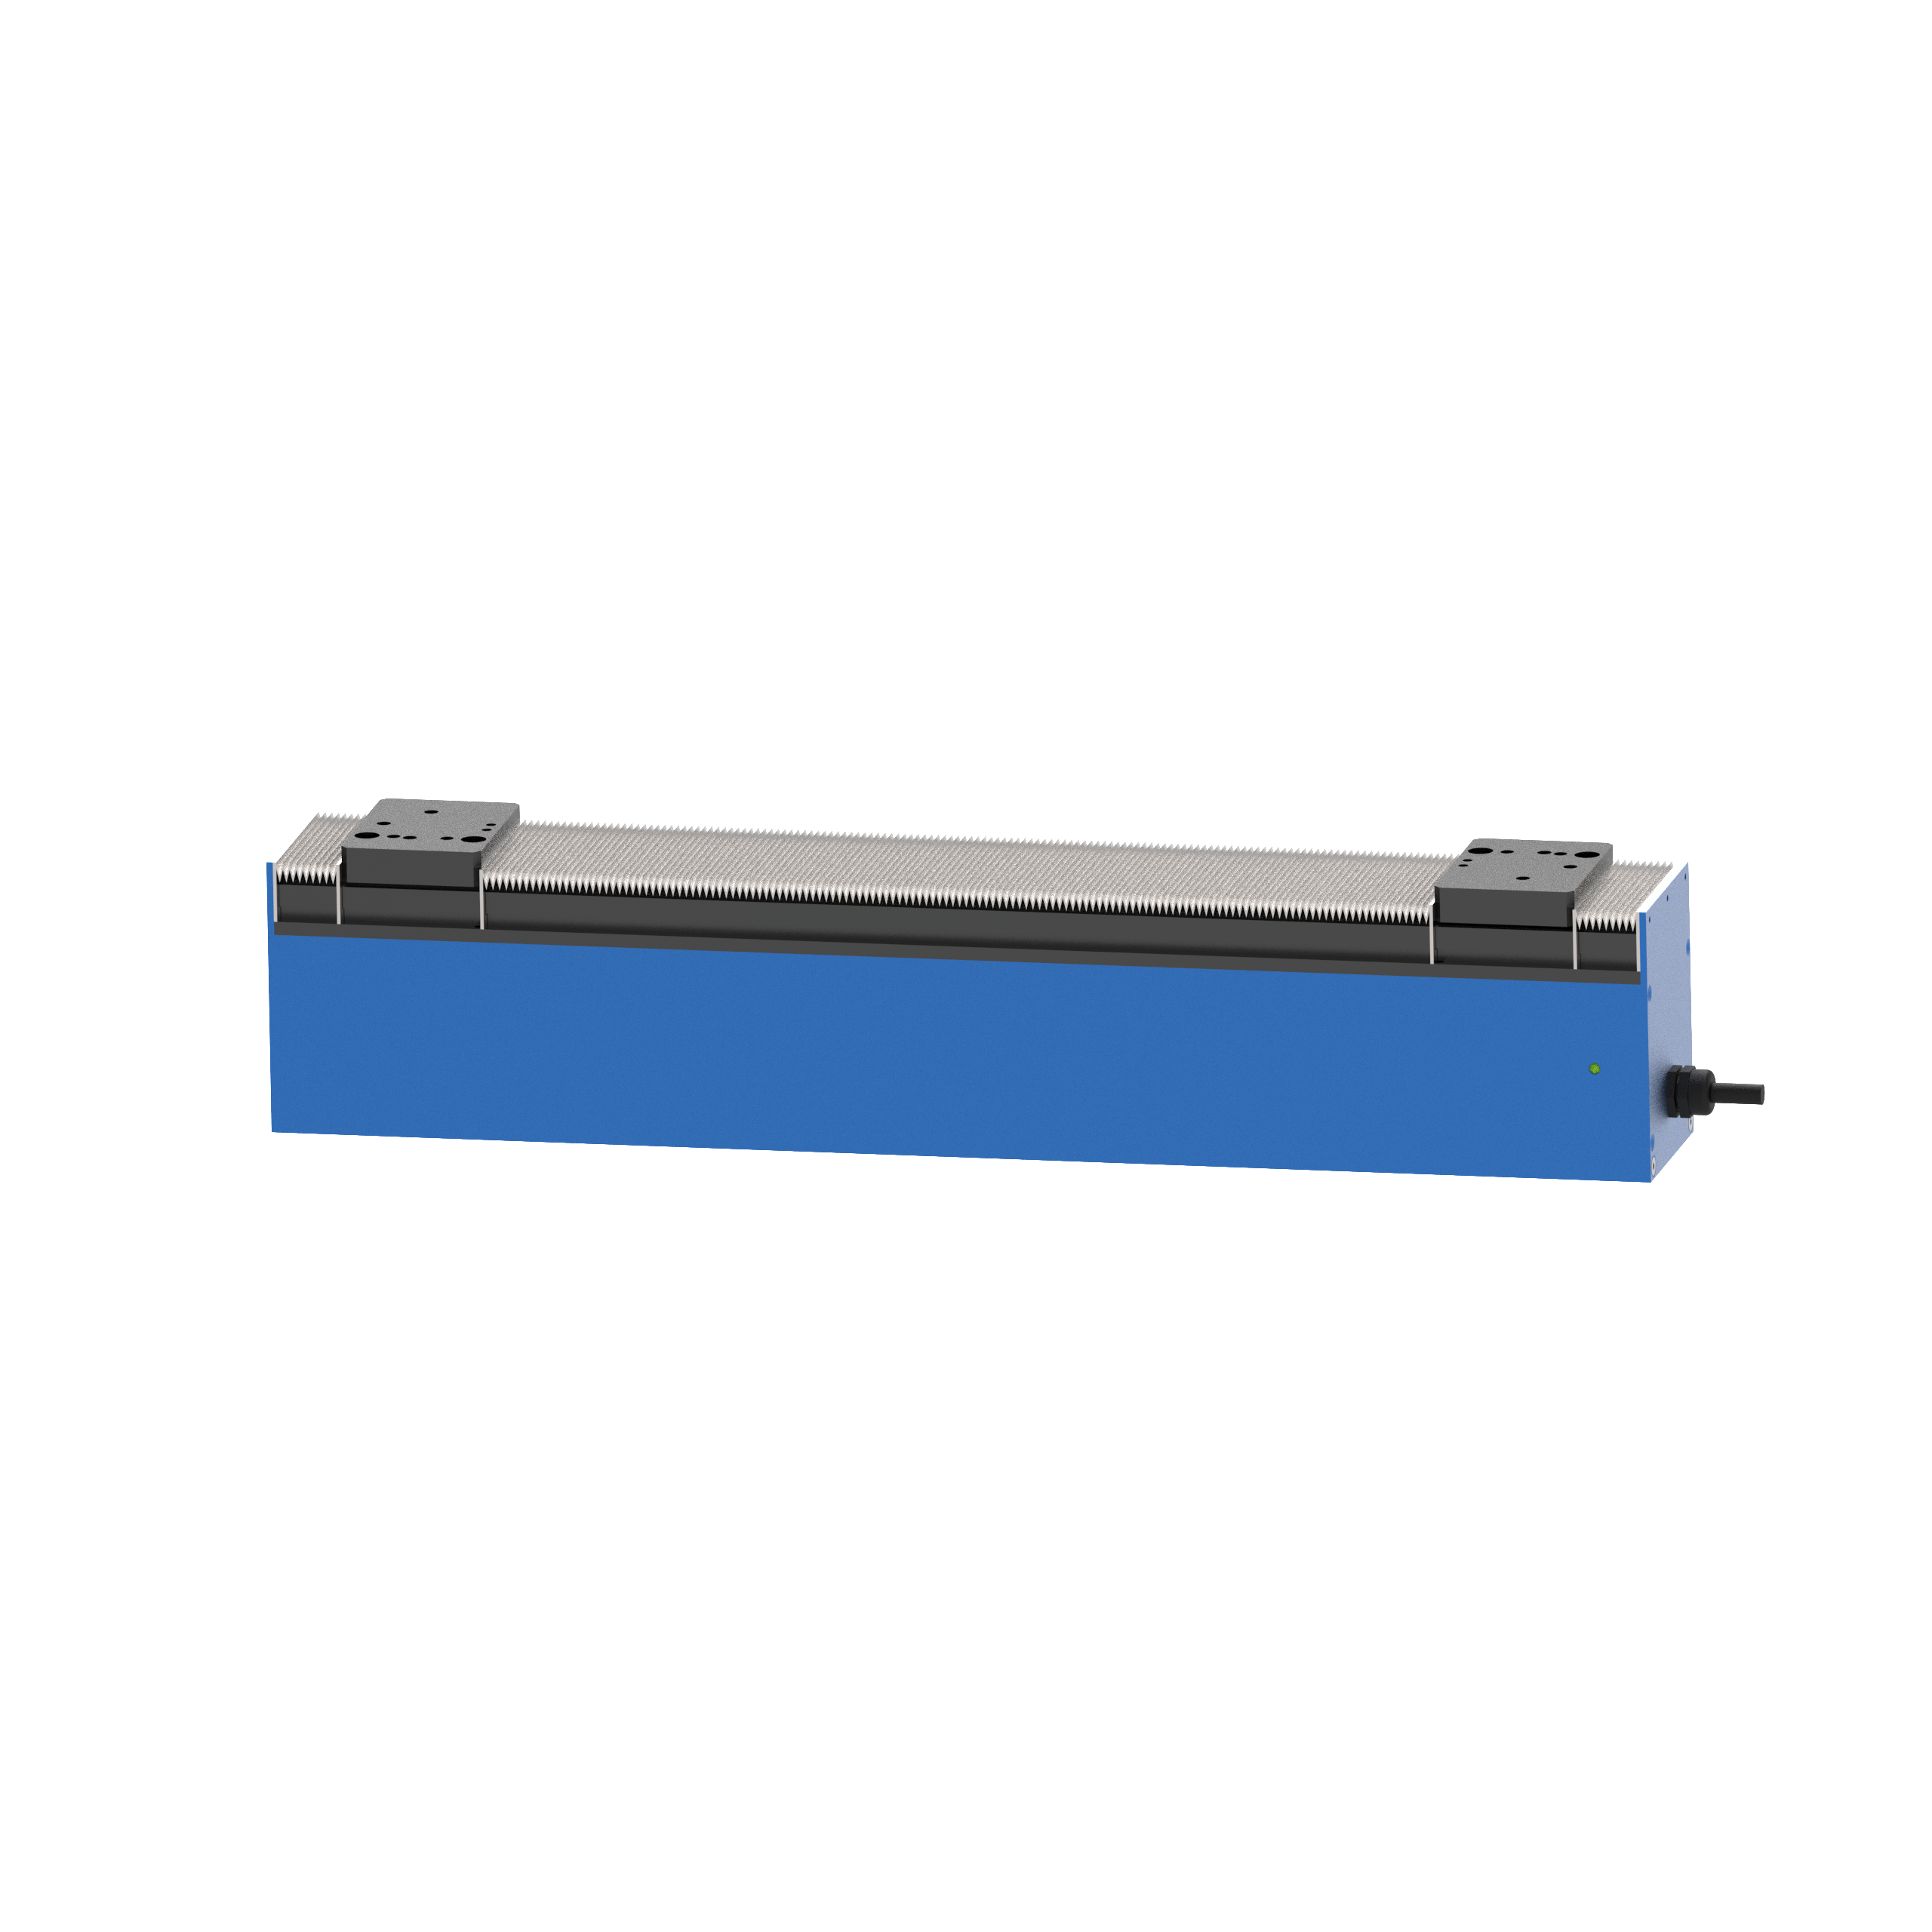
Technical profile and model data
Overview
Use the checks below to review EPGL-200-1200 against your workpiece, tooling and controller.
- Check the required opening and clearance across the full range of workpiece sizes.
- Confirm finger length, load position and retention throughout the move.
- Request current specifications and include any drawings or wiring information you need.
Technical specifications
These reference values come from the exact-model product header. Request a current model-specific datasheet to confirm the configuration, load conditions and electrical interface.
| Max. working stroke | 200 mm |
|---|---|
| Gripping force | 15–1200 N |
| Max. recommended clamping load | 12 kg |
| Open/close time (one way) | 3.5 s |
| Machine weight | Available on request |
| Operating voltage | Available on request |
| Communication | Available on request |
Confirm the stroke definition, force conditions, finger design and workpiece before ordering. Request current values for unlisted fields.
Detailed description, features, and application notes
These reference values come from the exact-model product header. Request a current model-specific datasheet to confirm the configuration, load conditions and electrical interface.
EPGL-200-1200 is presented by the manufacturer as an integrated drive-and-control heavy-load gripper. For a substantial workpiece, selection begins with the load path through the contacts, fingers, mounting adapter and handling machine.
Review the complete load path
Send the workpiece geometry, mass and centre of gravity, together with its pickup and placement orientations. A large contact area can still slip if the surface condition changes. Include oily, coated or uneven surfaces and identify whether shape-based support is possible.
Transferring a substantial component
For a component transferred into an assembly fixture, show how the part is supported before release. Check clearance around the fully open fingers and the space needed to withdraw the tool. Consider the effect of the workpiece on access to adjacent stations.
Dynamic loading and structure
Review the acceleration, stopping motion and offset of the load from the mounting face. Include the mass and length of custom fingers. Confirm the permissible loads and moments with the exact configuration documents; headline force or payload figures alone do not complete the calculation.
Retention and cell controls
Request the exact wiring and controller information, including fault response and behaviour after loss of power. Define a part-retention and recovery method appropriate to the cell. Verify cycle requirements using the complete movement and settling sequence.
Environment and contact design
Describe dust, liquid exposure and cleaning methods before requesting a configuration. Protection options mentioned in general web prose require exact documentation; no particular enclosure rating is established here.
EPGL-200-1200 questions
Does the model name state the usable opening?
Use the verified parameter fields and exact drawing; do not decode the name as an opening limit.
What is needed for a handling trial?
Supply representative parts, proposed fingers and the intended motion profile, with clear retention and surface-marking acceptance criteria.
Request an EPGL-200-1200 load-path review. Compare electric gripper models.
Need drawings, parameter sheets, or controller notes?
Ask for the current model-specific drawings, specifications and controller notes. Include the model, robot or controller, application, quantity and destination country.
Application checks for EPGL-200-1200
Confirm finger design, part contact area, cycle time, and robot payload before final selection.
Model questions
How should the fingertips be selected?
Match the fingertips to the part geometry, contact surfaces and required force. Send the part drawing for application review. See our finger design guide.
Before quotation
Send part size, part weight, robot model, finger length, cycle time, destination country, and quantity.