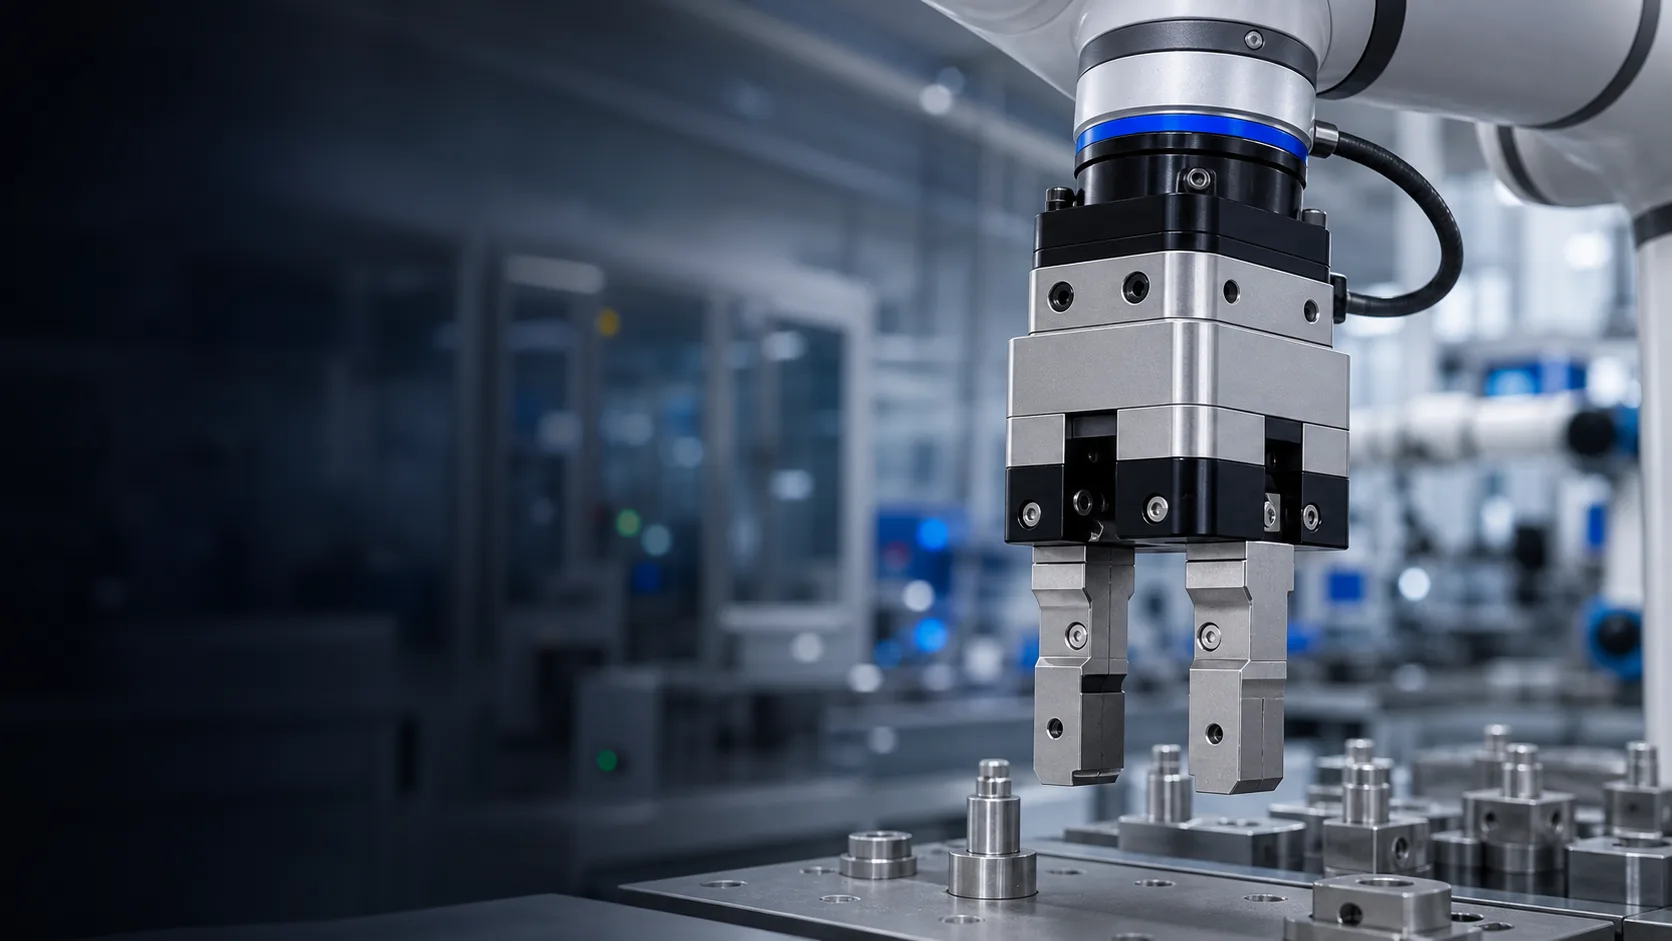
Find the right
electric gripper.
Electric grippers for automation integrators and machine builders — parallel, rotary and cobot models with Modbus RTU and I/O control. Send your part and robot; we reply with a matched model and quote within 24h.
What does your part need to do?
Use these paths to explore a series. Confirm the individual model against your operating conditions.
Start with ERG & ERGD.
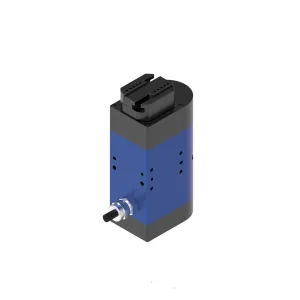
ERG-20-80
Grip and rotate automation
- Stroke
- 20 mm
- Rated gripping force
- 24–80 N
- Payload
- 1 kg
- Control
- I/O (NPN) or Modbus RTU (RS485)
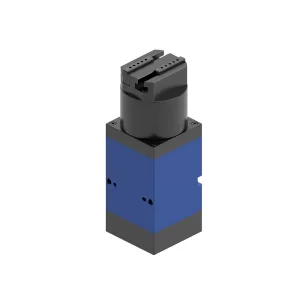
ERGD-30-35
Grip and rotate automation
- Stroke
- 30 mm
- Rated gripping force
- 10–35 N
- Payload
- 0.35 kg
- Control
- I/O (NPN) or Modbus RTU (RS485)
EPGS-6-10
Compact pick-and-place
- Stroke
- 6 mm
- Rated gripping force
- 10 N ±20%
- Payload
- 0.2 kg
- Control
- I/O
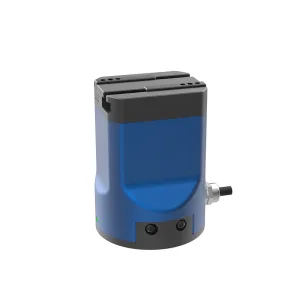
EPGC-50-150
Cobot workcells
- Stroke
- 50 mm adjustable
- Rated gripping force
- 40–150 N adjustable
- Payload
- 3 kg
- Control
- I/O (NPN) or Modbus RTU (RS485)
A useful conversation
starts with the part.
Give the gripper a clear task before choosing a model. These three checks help frame a selection request. Need a DH-Robotics PGE alternative? Compare stroke, rated gripping force, payload and control against EPG2 parallel grippers. Need an OnRobot RG2 alternative? Compare stroke, gripping force, payload and control with the EPG2-100-50.
Read the selection guide ↗- 01
Describe the workpiece
Dimensions, weight, contact surfaces and how the part is presented.
- 02
Define the cell
Robot or axis, mounting space, cycle target and available controller.
- 03
Review the model
Compare stroke, force and control; request the drawings needed to check the fit.
Make the next check easier.
Electric or pneumatic?
Compare the considerations before choosing an actuation approach.
Read guide ↗ Mechanical fitHow much gripping force?
Review force alongside contact, finger geometry and motion.
Read guide ↗ Control & wiringCheck the interface.
Understand the control requirements before planning integration.
Read guide ↗A few practical answers.
Where should I start if I do not know the model?
Start with the workpiece dimensions and weight, required motion and controller. Browse the task paths above or send these details through the inquiry page.
Can I check specifications before asking for a quote?
Yes. Compare the published values in the product center and open a model for its specifications. Ask for current drawings and confirm the operating conditions before ordering.
What should I include in an inquiry?
Include the model if known, part dimensions and weight, robot or controller, cycle target, quantity and destination country. Mention any drawing or wiring information you need.
Let’s narrow down the options.
Share your task and the model you are considering.