LEHF20-S24 Electric Gripper
LEHF20-S24 is listed in the LEHF series for industrial automation. Listed control: Q programmable / QS programmable + Modbus (selection code). Compare the model data with your workpiece and installation requirements.
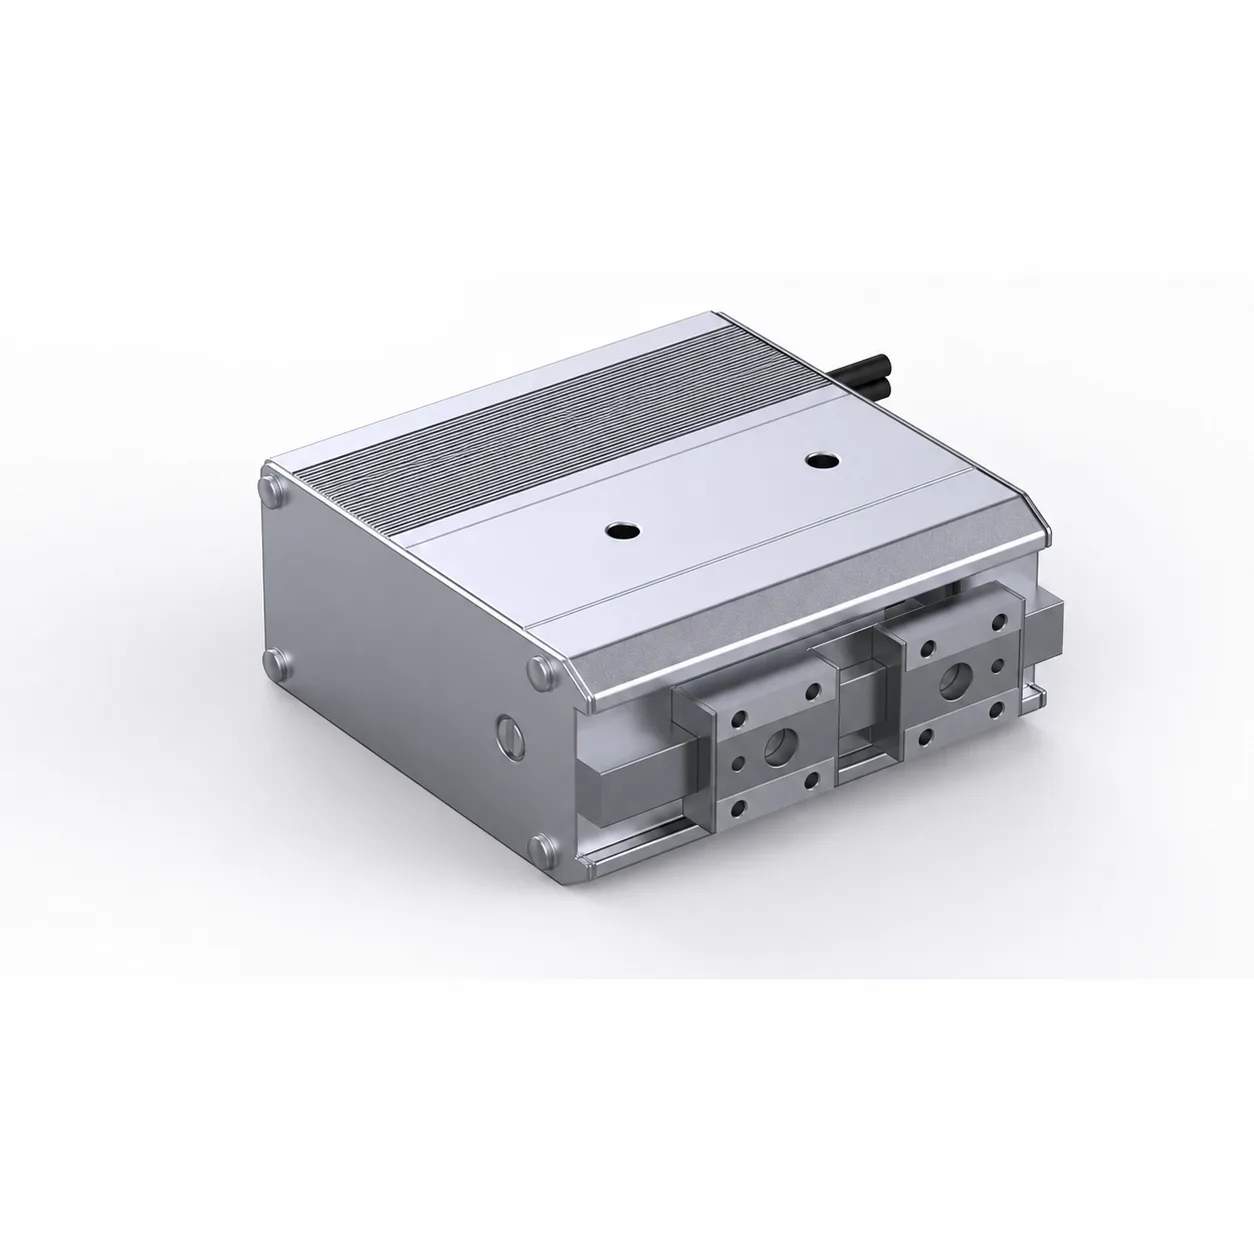
Technical profile and model data
Overview
Use the checks below to review LEHF20-S24 against your workpiece, tooling and controller.
- Request the current travel definition and check it against your part and installation.
- Confirm the mounting arrangement, load position and required holding conditions.
- Request current specifications and include any drawings or wiring information you need.
Technical specifications
Request the exact model and configuration documentation before selection; numeric ratings and the control interface have not been verified for this model.
| Max. working stroke | 24 mm |
|---|---|
| Rated gripping force | 11–28 N |
| Max. recommended clamping load | Available on request |
| Open/close time (one way) | Available on request |
| Machine weight | 0.61 kg |
| Operating voltage | Available on request |
| Communication | Q programmable / QS programmable + Modbus (selection code) |
| Positional repeatability | ±0.05 mm |
| Cable length | 3 m or 5 m; right or left exit |
| Travel speed | 5–30 mm/s |
| Drive | T-type screw rod |
| Guide | Linear guide |
| Finger clearance | 0.5 mm |
| Motor | 28 stepper motor with encoder |
| IP grade | Available on request |
| Operating environment | 0–40 °C, ≤85% RH |
Confirm the stroke definition, force conditions, finger design and workpiece before ordering. Request current values for unlisted fields.
Detailed description, features, and application notes
Request the exact model and configuration documentation before selection; numeric ratings and the control interface have not been verified for this model.
LEHF20-S24 is described consistently on its exact manufacturer page as an electric parallel gripper. Detailed performance and controller specifications still need exact-configuration documentation, so begin the enquiry with the workpiece and installation requirements.
Parallel gripping requirements
Show the surfaces available for opposing contact and the smallest and largest gripping widths. Include part tolerances and the approach direction. Check whether the fingers can reach stable areas without touching a fragile edge, connector or nearby fixture.
Moving a component into a nest
For a pick-and-place enquiry, identify how the component is presented at pickup and how the receiving nest supports it. Explain whether the gripper must maintain orientation throughout travel or simply deliver the part to a locating fixture.
Opening and loading questions
Provide the required opening, part mass, robot acceleration and proposed fingertip length. Request confirmation of how the quoted stroke is defined and how gripping force is measured. Do not use values from another manufacturer’s similarly named series to complete the selection.
Confirm the electrical configuration
Send the robot or PLC reference and ask for the exact supply, wiring and communication specification. Define the grip-confirmation and release signals needed by the cell. Interface and feedback capabilities should be checked against the supplied configuration before programming.
Drawings before tooling
Request the mounting pattern and fingertip-interface drawing before designing adapters or contact pads. Include acceptable surface marks, part variants and the required changeover method in the review.
LEHF20-S24 questions
Are dimensions and control interfaces confirmed?
The available exact page establishes the product type, but does not provide an adequate exact-model engineering sheet for these details.
What should be sent for a quotation?
Send the part drawing, required opening, contact plan, mounting layout and controller details, and request the matching parameter and electrical documents.
Request the LEHF20-S24 exact-configuration documents. Compare electric gripper models.
- Typical lead time: 7 days, confirm on quote
- 12-month warranty
Need drawings, parameter sheets, or controller notes?
Ask for the current model-specific drawings, specifications and controller notes. Include the model, robot or controller, application, quantity and destination country.
Application checks for LEHF20-S24
Confirm finger design, part contact area, cycle time, and robot payload before final selection.
Model questions
Which control interface is listed?
Q programmable / QS programmable + Modbus (selection code). Confirm the supplied pinout and controller configuration for this model.
How should the fingertips be selected?
Match the fingertips to the part geometry, contact surfaces and required force. Send the part drawing for application review. See our finger design guide.
Before quotation
Send part size, part weight, robot model, finger length, cycle time, destination country, and quantity.