LEF20-S10 Electric Parallel Gripper
LEF20-S10 is an electric parallel gripper (stepper-driven, with encoder), with 10 mm stroke and 15–40 N gripping force.
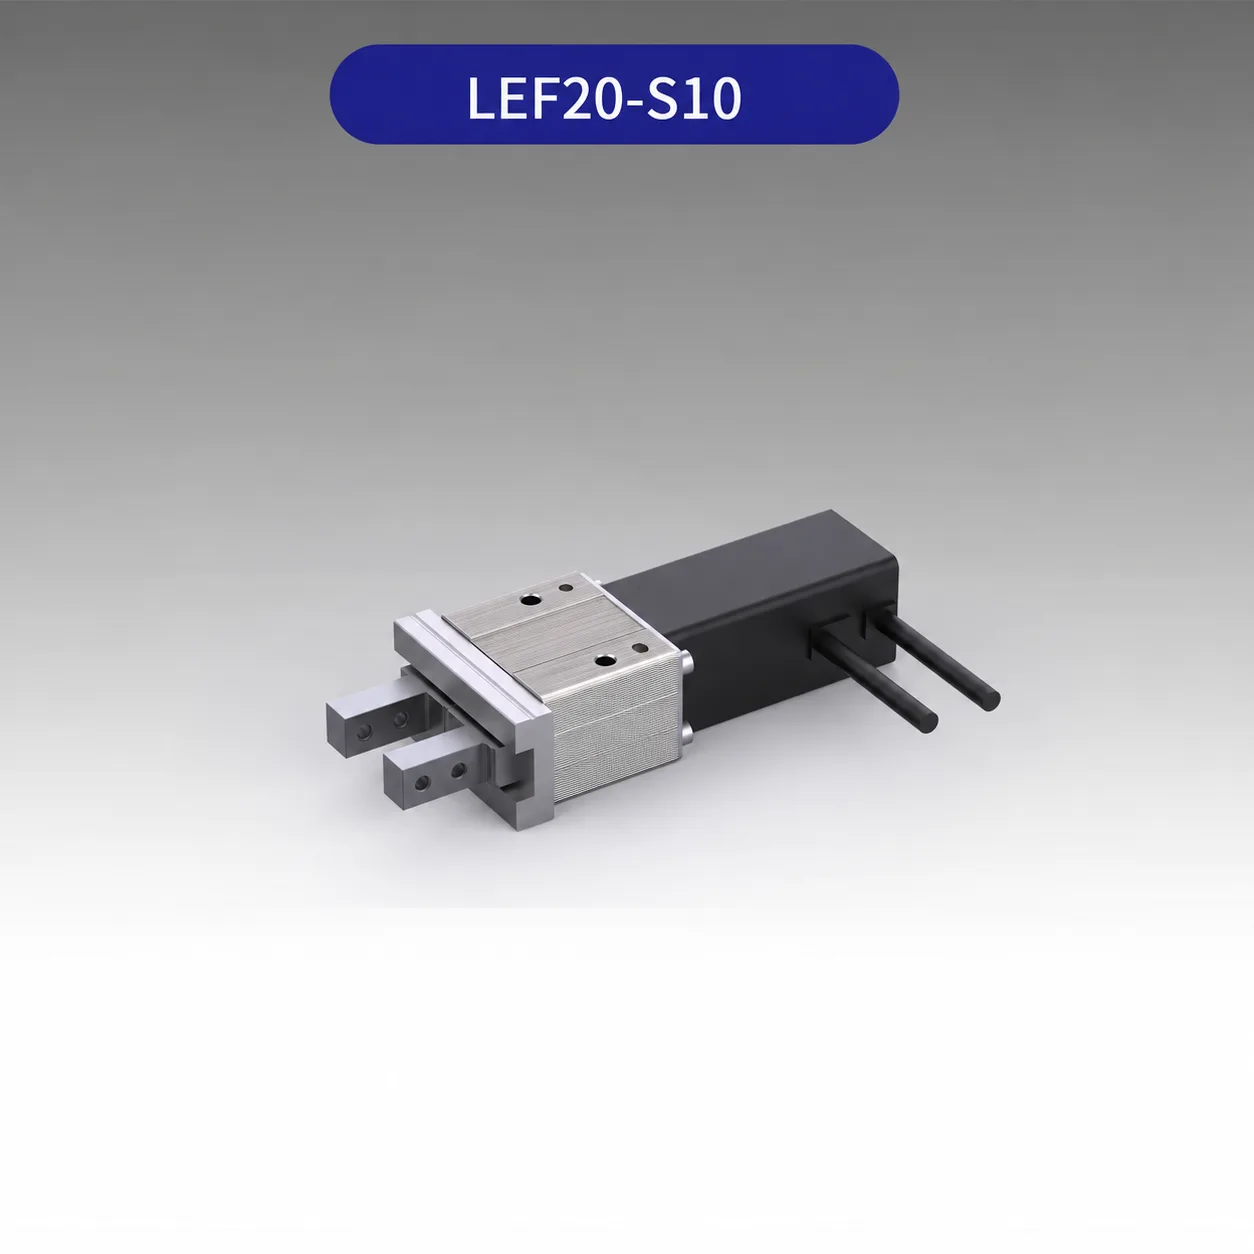
Technical profile and model data
Overview
Use the checks below to review LEF20-S10 against your workpiece, tooling and controller.
- Check the 10 mm stroke and finger clearance against the workpiece.
- Request the permitted loads, mounting orientation and matching drive information.
- Request current specifications and include any drawings or wiring information you need.
Technical specifications
Parameters from 夹爪工程师; PM Jojo approved, 2026-11-02. Supply voltage, protection rating and Modbus protocol details: On request.
| Type | Electric parallel gripper (stepper-driven, with encoder) |
|---|---|
| Stroke | 10 mm |
| Rated gripping force | 15–40 N |
| Speed | 5–50 mm/s |
| Repeatability | ±0.02 mm |
| Finger clearance | 0.5 mm |
| Weight | 0.42 kg |
| Motor/drive | 28 stepper motor with encoder, lead screw + cam, linear guide |
| Controller | Q (programmable) / QS (programmable + Modbus) |
| Cable | none / 3 m (standard) / 5 m |
| Operating environment | 0–40 °C, below 85% RH |
| Supply voltage | On request |
| Protection rating | On request |
| Modbus protocol details | On request |
Confirm the stroke definition, force conditions, finger design and workpiece before ordering. Request current values for unlisted fields.
Detailed description, features, and application notes
Parameters from 夹爪工程师; PM Jojo approved, 2026-11-02. Supply voltage, protection rating and Modbus protocol details: On request.
LEF20-S10 is an electric parallel gripper (stepper-driven, with encoder) with a linear guide.
Control and cable options
Controller: Q (programmable) / QS (programmable + Modbus). Cable: none / 3 m (standard) / 5 m.
Applications
- Material transfer / automatic loading and unloading
- Electronic components
- 3C electronics
Supply voltage, protection rating and Modbus protocol details: On request.
Typical lead time: 7 days, confirm on quote. 12-month warranty.
Need drawings, parameter sheets, or controller notes?
Ask for the current model-specific drawings, specifications and controller notes. Include the model, robot or controller, application, quantity and destination country.
Application checks for LEF20-S10
Confirm finger design, part contact area, cycle time, and robot payload before final selection.
Model questions
Which control interface is listed?
Q (programmable) / QS (programmable + Modbus). Confirm the supplied pinout and controller configuration for this model.
What supply voltage is listed?
On request. Check the current wiring document for the supplied configuration.
What protection rating is listed?
On request. Confirm suitability for your actual environment.
How should the fingertips be selected?
Match the fingertips to the part geometry, contact surfaces and required force. Send the part drawing for application review. See our finger design guide.
Before quotation
Send part size, part weight, robot model, finger length, cycle time, destination country, and quantity.